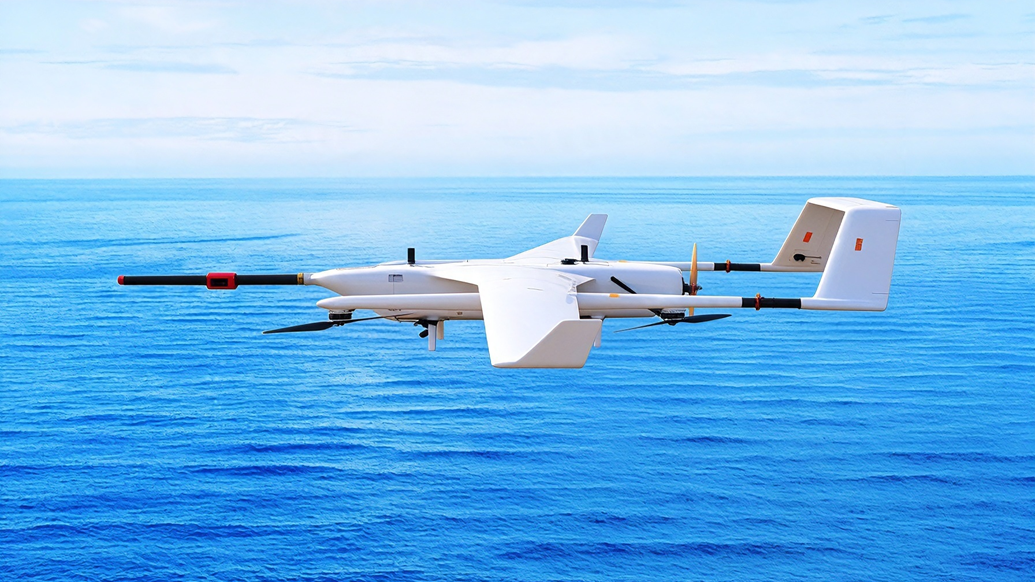
The Fengpeng Zhengju FH hybrid-wing aeromagnetic system features a highly integrated design: LiDAR, wireless data link and RTK are shared with the aeromagnetic payload to remove redundant sensors. This unified architecture ensures...
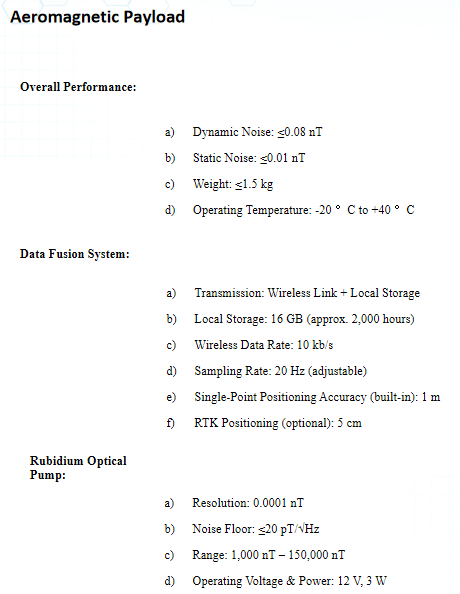
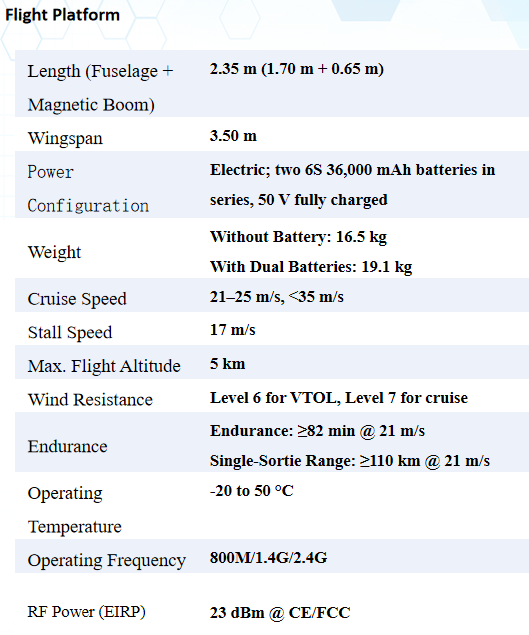
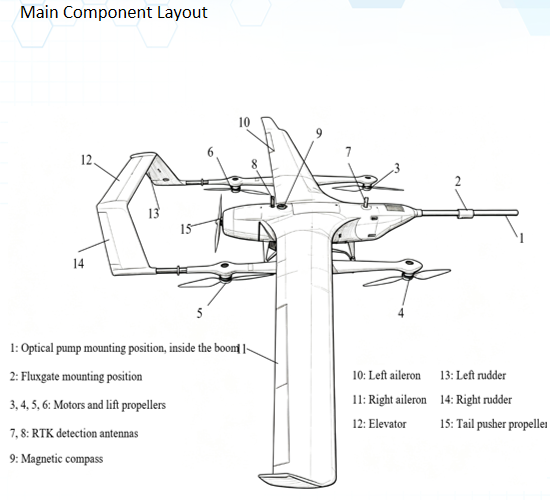
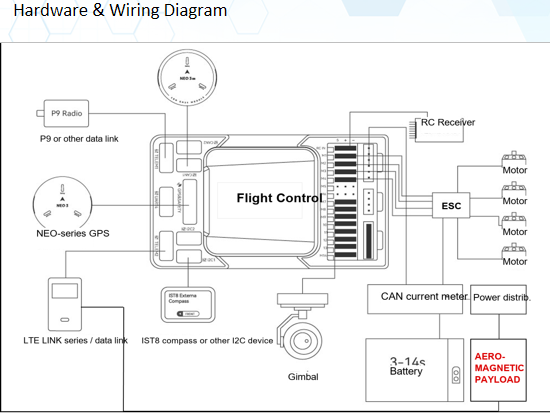
The core parameters of moving-platform magnetic detection — both static and dynamic noise — reach Class I aeromagnetic standards
With the magnetic payload onboard, dynamic endurance reaches 80 min and a range of 112 km, meeting diverse mission requirements
Real-time communication range up to 15–20 km, ensuring smooth information flow in remote operations
No runway required; a 5 m × 5 m area suffices for take-off and landing, with support for shipboard operations at 3 knots
Modular design for quick assembly — deployment in ≤3 min and pack-up in ≤2 min
It can detect large ferromagnetic objects such as mineral deposits, cables and various vehicles.
4–6× the target maximum linear dimension; after compensation, performance rises ~30% (site-dependent).
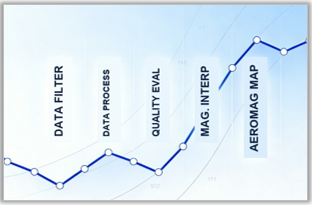
The FOM-TL algorithm is used, fitting parameters to complete aeromagnetic data compensation and correction.
With calibration/compensation, ultra-low system noise resolves 2 nT weak magnetic signals.
Ensure safe landing: round-trip plus survey-area distance must stay below total range.
Yes; the medium neither affects sensor operation nor attenuates the magnetic field.
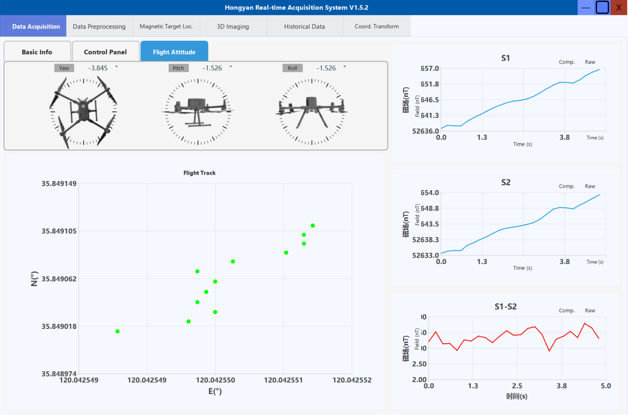
Software System
Environment: Windows 11 Home 22H2, 1920×1080 display, ≥8 GB RAM, Intel i5-8400 @ 2.8 GHz, discrete GPU (e.g. GTX 1650)
How to Use
a) Real-Time: real-time parsing, display, storage, filtering and compensation
b) Preprocessing: anomaly filtering, gradient removal and attitude compensation
c) One-Click Mapping: split tracks; generate magnetic-field maps; switch coordinates and view track magnetic curves
d) Target Location: integrated YOLO algorithm for fast magnetic-map inspection and marking suspected targets
e) 3D Imaging: one-click 3D target distribution map
f) History: load, preview, delete and export data
Environment: Windows 11 Home 22H2, 1920×1080 display, ≥8 GB RAM, Intel i5-8400 @ 2.8 GHz, discrete GPU (e.g. GTX 1650)
Software System
Environment: Windows 11 Home 22H2, 1920×1080 display, ≥8 GB RAM, Intel i5-8400 @ 2.8 GHz, discrete GPU (e.g. GTX 1650)
How to Use
a) Real-Time: real-time parsing, display, storage, filtering and compensation
b) Preprocessing: anomaly filtering, gradient removal and attitude compensation
c) One-Click Mapping: split tracks; generate magnetic-field maps; switch coordinates and view track magnetic curves
d) Target Location: integrated YOLO algorithm for fast magnetic-map inspection and marking suspected targets
e) 3D Imaging: one-click 3D target distribution map
f) History: load, preview, delete and export data
Environment: Windows 11 Home 22H2, 1920×1080 display, ≥8 GB RAM, Intel i5-8400 @ 2.8 GHz, discrete GPU (e.g. GTX 1650)
Basic Package (Required)
a) UAV magnetic detection system
b) Real-time data acquisition software
c) Optical pump